|
I am a Research Intern at RideFlux, where I work on autonomous driving.
I received my B.S. in Electrical Engineering from Kookmin University, where I worked with Prof.
Seongwon Lee on 3D/4D scene understanding.
Previously, I was a Research Intern at CARIAD, advised by Dr.
Xavier Timoneda.
Email / Google Scholar / Github / CV |
|
|
My long-term goal is to develop world models that enable autonomous agents to understand the physical world, predict the consequences of their actions, and make reliable decisions. I am particularly interested in representations for action and multi-agent counterfactual world modeling, decision-relevant representations and predicting how the world and other agents may respond to different actions. Building on my work in 3D/4D scene understanding and autonomous driving, I aim to bridge perception, world modeling, and decision-making. |
|
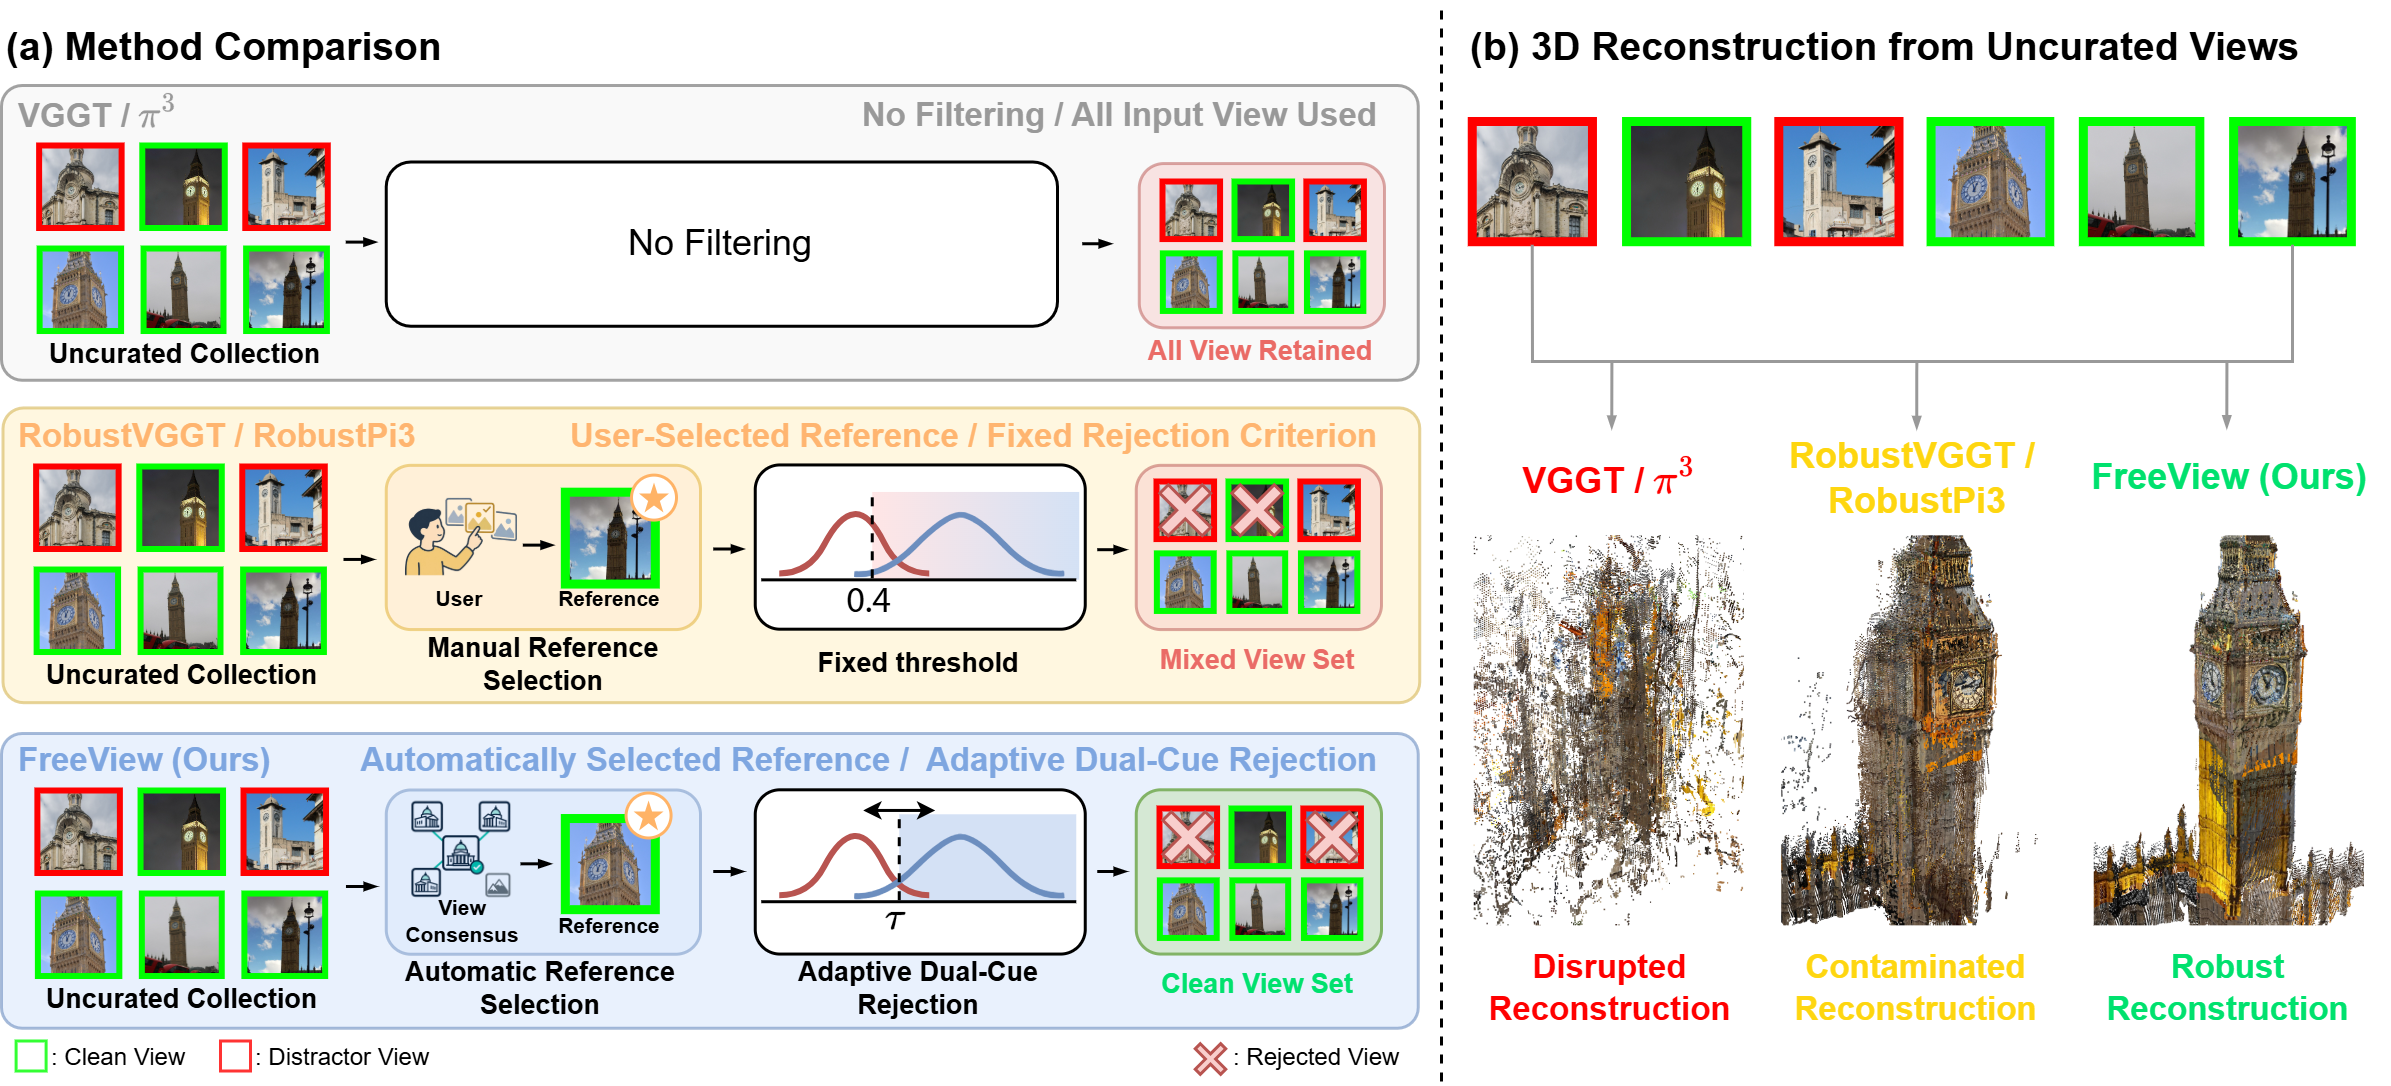
Consensus-based visual-geometric distractor rejection for robust 3D reconstruction
Junho Kim*, Hyunyoung Choi*,
Seongwon Lee†
Submitted to ICRA'27 arXiv |
|
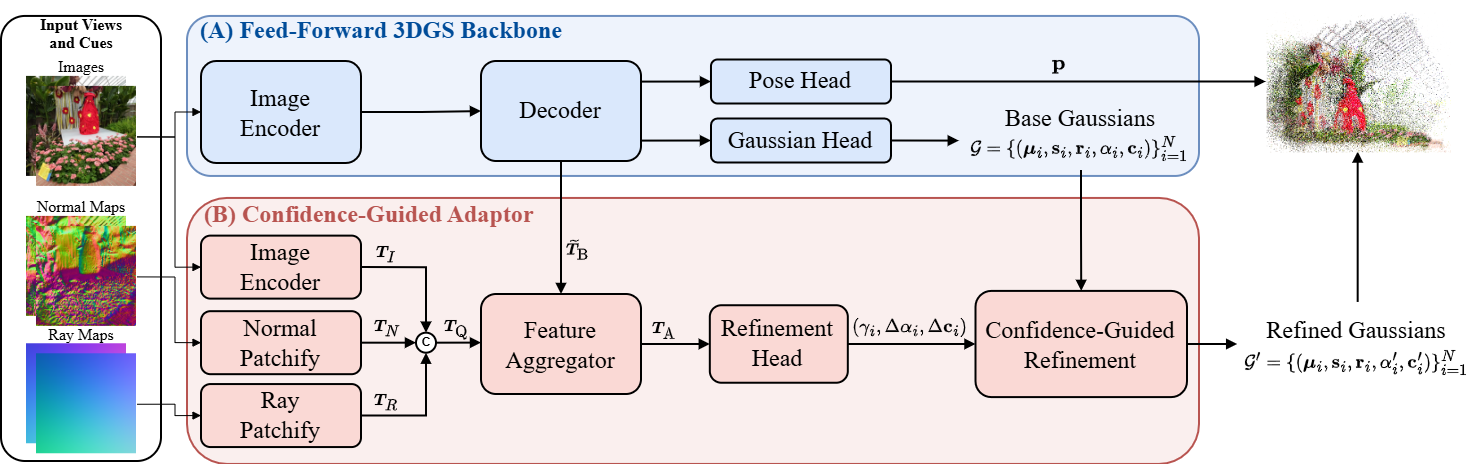
A plug-and-play module that selectively corrects low-confidence appearance predictions.
Junho Kim, Jiseok Kim,
Seongwon Lee†
International Conference on Control, Automation, and Systems (ICCAS), 2026 arXiv |
|
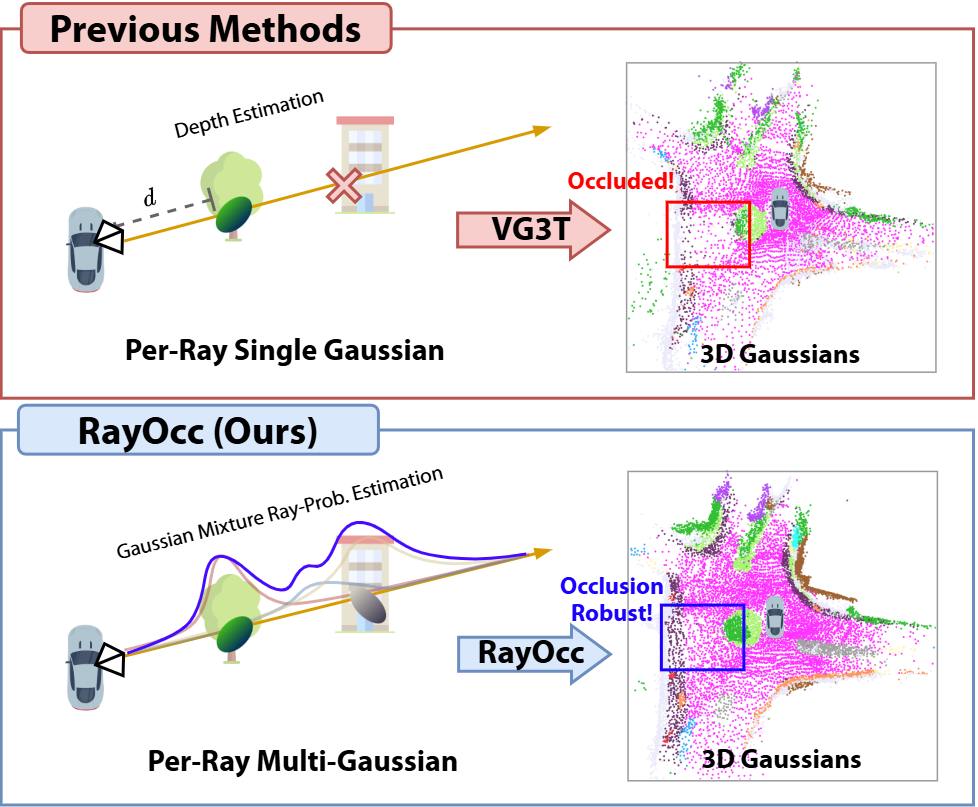
Multi-surface Ray occupancy modeling with Gaussian mixture model.
Junho Kim,
Seongwon Lee†
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2026 project page / arXiv |
|
Cross-view geometry grounding produces cleaner 3D occupancy with fewer Gaussians.
Junho Kim,
Seongwon Lee†
IEEE International Conference on Robotics and Automation (ICRA), 2026 project page / arXiv / code |
|
|
|
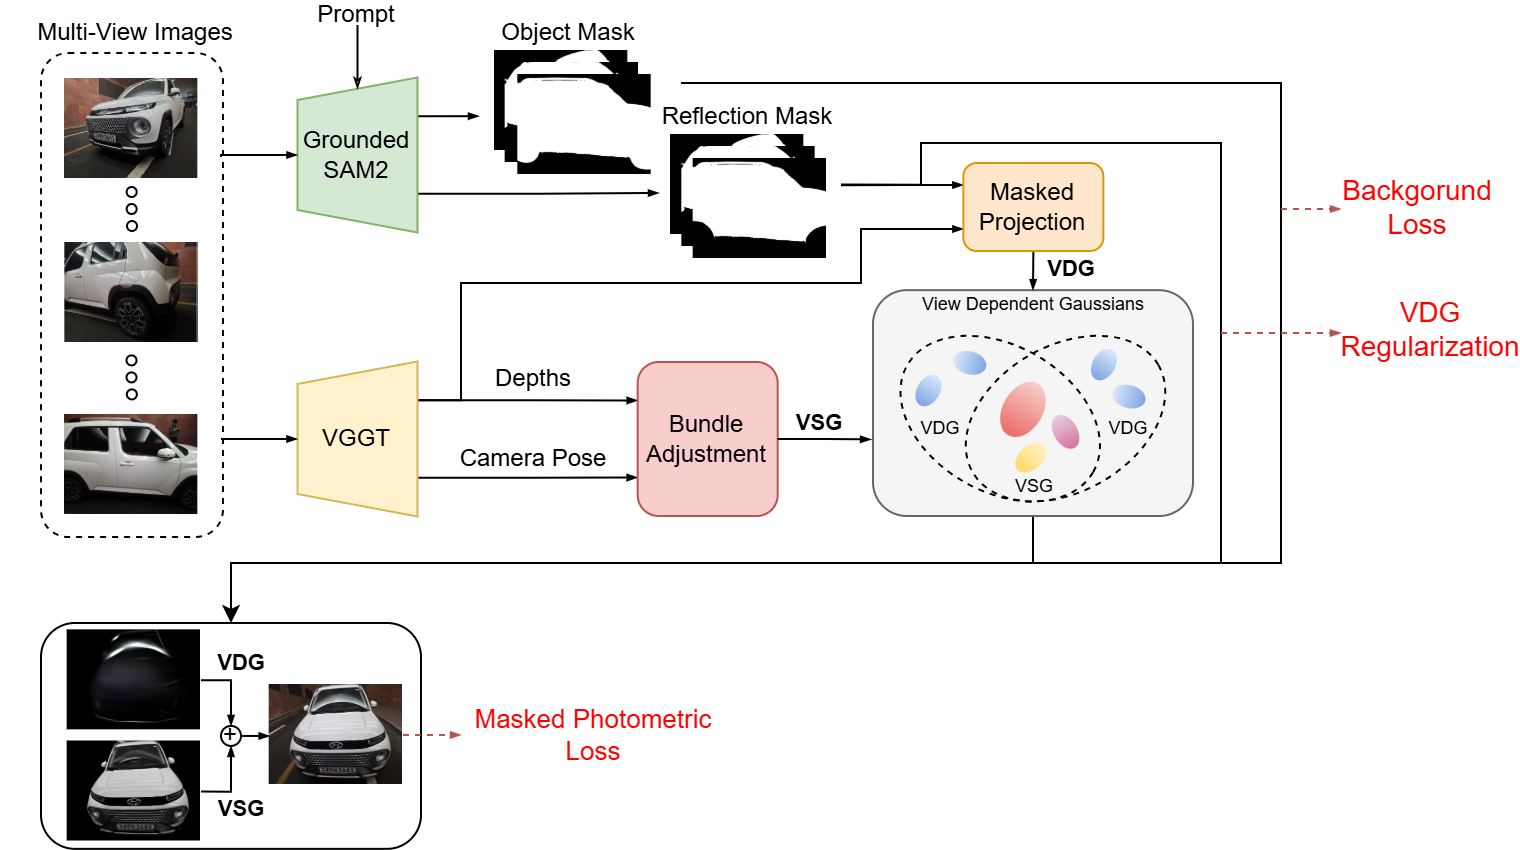
|
Reflective vehicle reconstruction with disentangled diffuse and specular appearance.
Junho Kim,
Sangho Byeon,
Jiseok Kim,
Seongwon Lee
Team Lead of We-Meet Project (Fall 2025) |
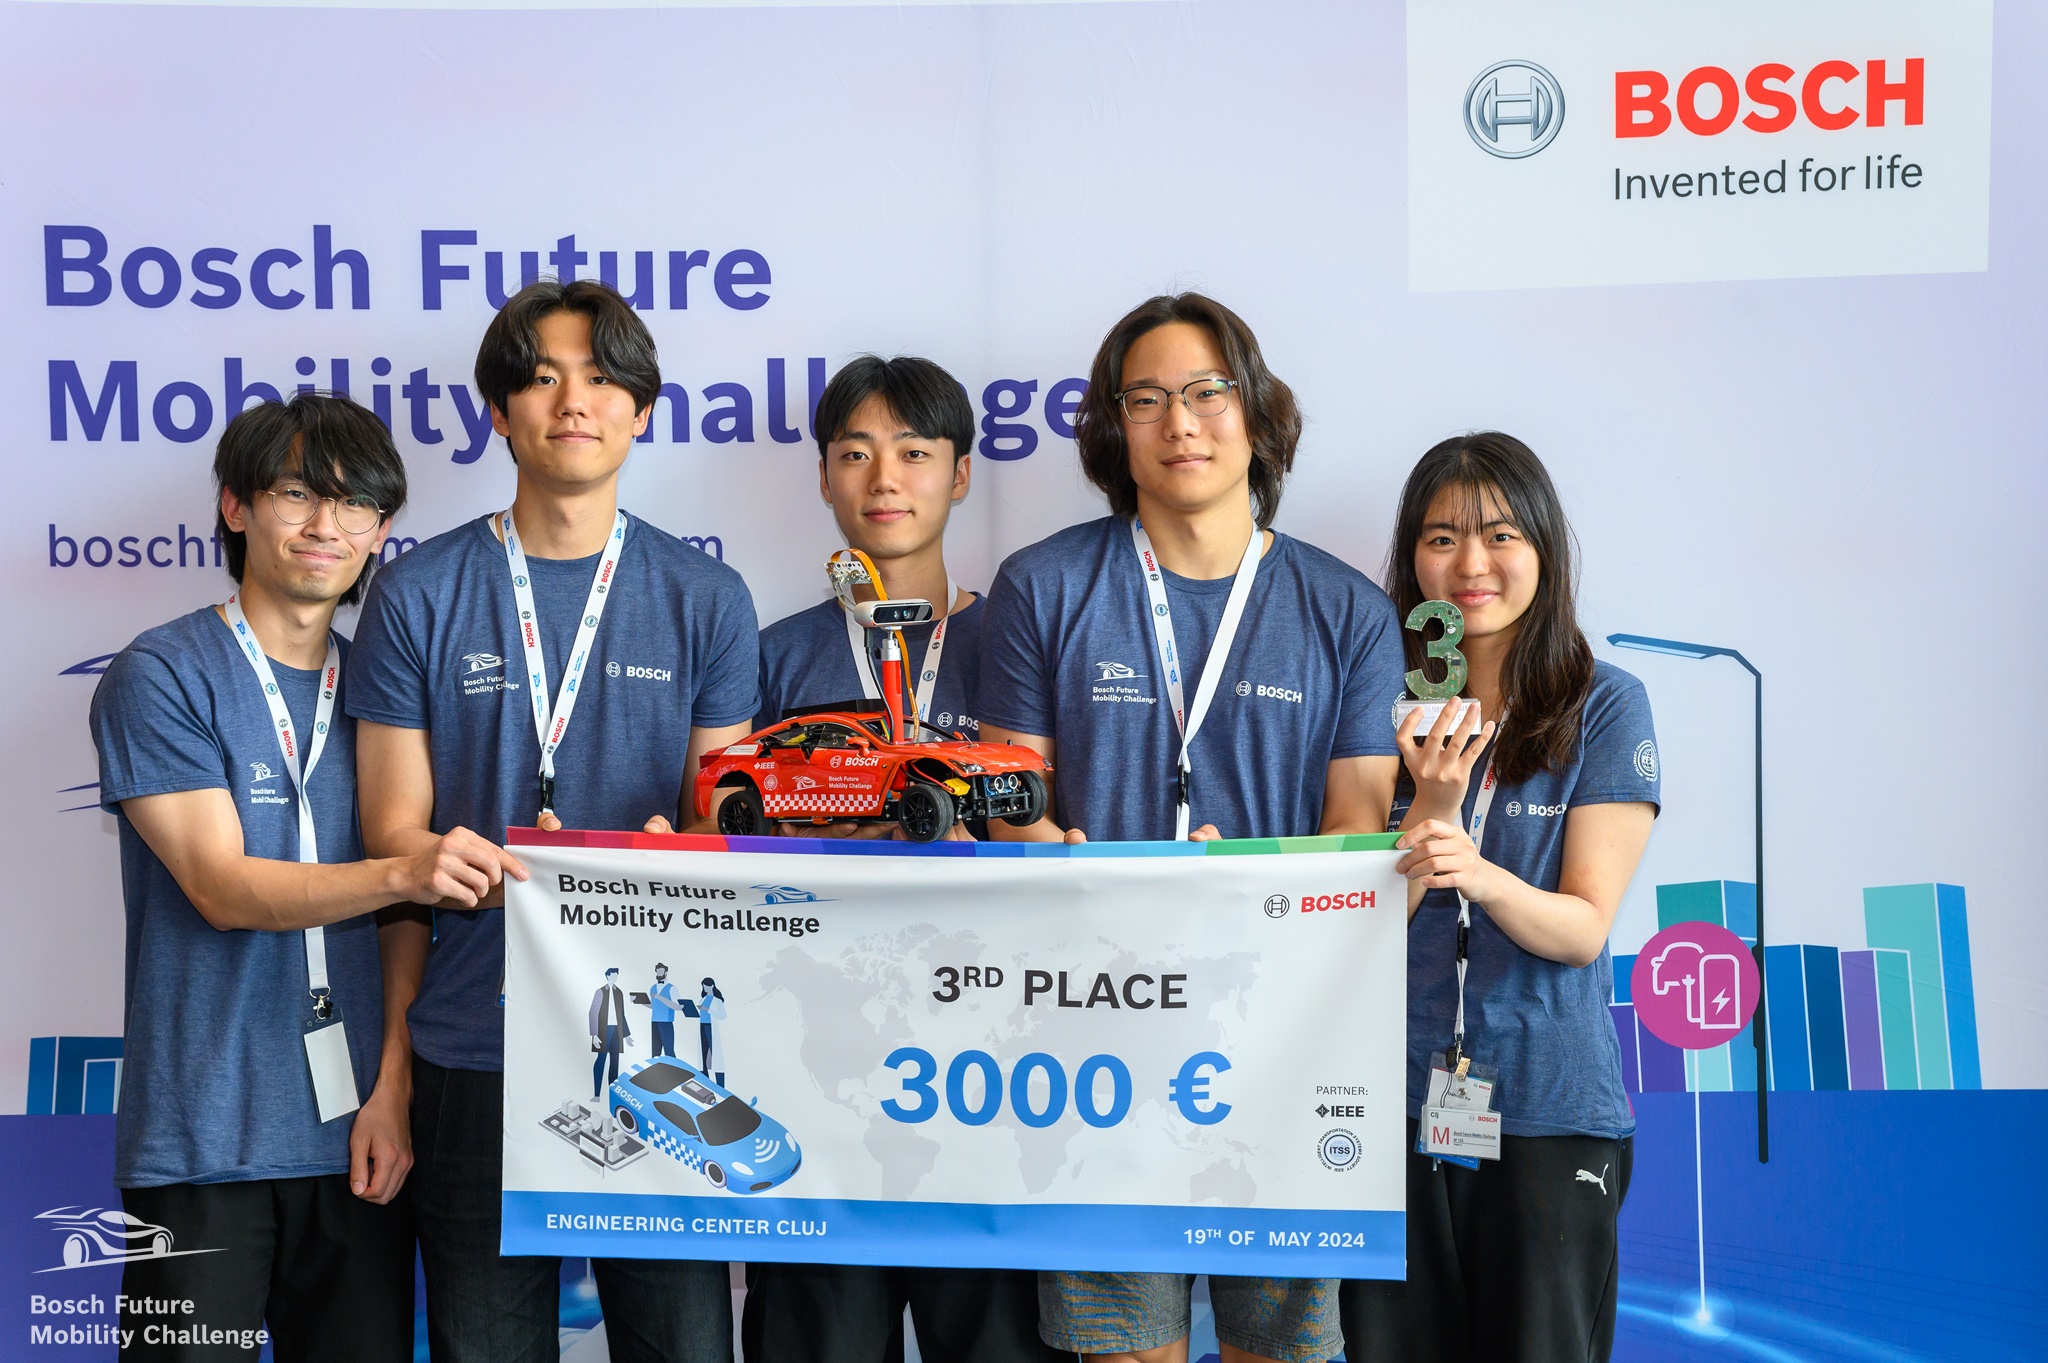
|
Real-time autonomous driving perception and deployment on an embedded platform.
Minchan Jeong,
Junho Kim,
Dahyeon Ko,
Jaehyoung Park,
Donghwan Seo
Perception Engineer / ROS, Multi-View 3D object detection, V2X 3rd Prize, (top 3 out of 80 teams worldwide) |
|
|
 |
RideFlux, Seoul, South Korea
2026.08 - Present Perception Research Intern Advisor: Dr. Hawook Jeong |
 |
Kookmin University, Seoul, South Korea
2019.03 - 2026.08 B.S. in Electrical Engineering Advisor: Prof. Seongwon Lee |
 |
CARIAD SE, Ingolstadt, Germany
2024.07 - 2024.12 Sensor Fusion Research Intern Advisor: Dr. Xavier Timoneda |
 |
SEA:ME, Wolfsburg, Germany
2023.07 - 2024.06 Out-Bound Program Advisor: Prof. Jongchan Kim |
 |
Republic of Korea Army, Gyeonggi-Do, South Korea
2020.12 - 2022.6 Mandatory Service |
|
Template stolen from Jon Barron and Yijia Weng . Thanks for stopping by :)
|